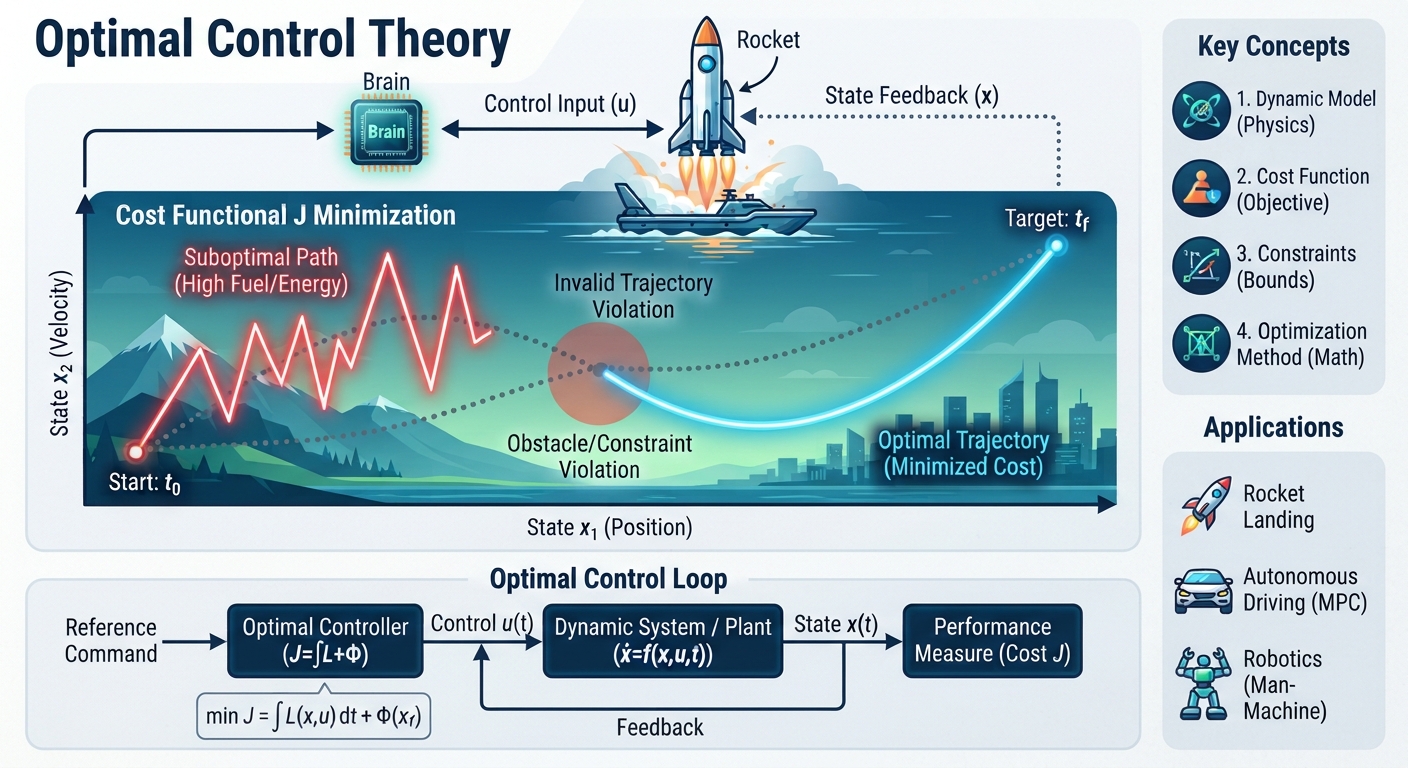
Control theory is an interdisciplinary branch of engineering and mathematics that deals with the behaviour of dynamical systems with inputs. The external input of a system is called the reference. When one or more output variables of a system need to follow a certain reference over time, a controller manipulates the system inputs to achieve the desired output. The usual objective of control theory is to calculate the proper corrective action from the controller that results in system stability, that is, the system will hold the set point and not oscillate around it. The course introduces some fundamental principles underlying Optimal Control for nonlinear/linear systems, Dynamic Programming, Variational Calculus, Pontryagin Minimum Principle and in its final section some Numerical Methods.
- Opettaja
Yury Nikulin